
A motivating example
Consider the following equation, where  :

You have most likely solved many equations such as these and would be able to conclude what  equals in a second or so. However, if we take our time solving the problem and consider all the steps necessary, we stumble upon the underlying rules that allow us to solve such equations. Writing out each step fully, we’d get something like this:

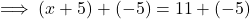
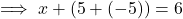
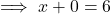

Writing all of this may seem a little long-winded but it reveals the rules- known as axioms- that allow us to do all of this. Firstly, we are able to write that 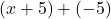 is the same as
 due to the more general rule that:
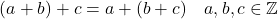
This is known as the property of associativity. Essentially, we have freedom over the order in which we add things. Next, the fact that 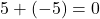 is a specific case of the more general rule that:

This arises from the fact that  is the additive inverse of
 . Two integers are additive inverses of one another when they sum to
 and you will probably be aware of the fact that every integer has a distinct additive inverse. Lastly, we know that
 since we know that generally:
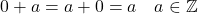
Summarised in words, when we add to an integer, we just get that integer. We refer to as the identity element. We also know one final thing: when we add two integers, we get another integer. Written succinctly, we have that:
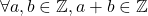
This is referred to as closure.
The Four Axioms
When we have some operation  and it is acting over some set,
 , we call the set with the operation a group when it satisfies the four axioms mentioned before:
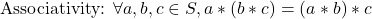
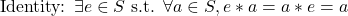

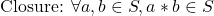
We denote a group with set and operation by  . There are many groups you likely have dealt with many times such as
 and
 . The set of all matrices with entries in
 and matrix multiplication as the operation is not a group since matrices that have a determinant equal to zero don’t have inverses. However, if we consider matrix multiplication with entries in over the set of invertible matrices, this does in fact form a group.
Examples
While the groups previously mentioned certainly are fascinating in their own right, we will now shift our attention to a group that we tend to not deal with much in pre-university mathematics, but is of enormous significance in group theory. I am speaking of the symmetric group on  letters, which revolves around rearrangements of the set
 . For the sake of simplicity, we’ll begin with
 , the symmetric group on
 letters. Here are some elements of the group:

Our operation is composition; here is an example of composing two elements:

Focusing on a single number, we see that the path of 3 is  . Notice that we read compositions of symmetries right to left like how we read the composition of functions. Generally, some element
 corresponds to rearranging the numbers 1, 2, 3 to
 where are distinct integers from 1 to 3. Notice that similarly to matrices, when composing two elements, we consider the element on the right first and then the element on the left. It is true that satisfies the four necessary axioms to be classified as a group, and generally, we have that
 is a group (the proof of this is left as an exercise for the reader).
What about the set 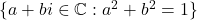 under multiplication- is this a group? Let’s have a look. It is clear that
 , which is thankfully in our set, will act as our identity, and we have associativity since complex multiplication is generally associative. The inverse of some
 is
 as
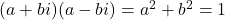 . To prove that we have closure, we consider some elements and
 and find their product then show it too is a complex number of the form
 that satisfies
 :


And thus, we have shown that the set under multiplication is indeed a group. We could have taken a more geometric approach too of course; our set is essentially all of the possible movements around the unit circle in the complex plane. Any two movements around the unit circle can just be considered as a singular combined movement, so we have closure. We can choose to not move around the unit circle at all and this would be our identity. It doesn’t matter in which order we apply movements around the unit circle so we have associativity. Finally, we clearly have an inverse for each movement since we just move in the opposite direction the same distance. My geometric explanation of course lacks rigour and isn’t as precise as my previous justification however it can provide us with some intuition as to whether or not we are dealing with a group.
Lastly, let’s consider a group predicated on rotating and flipping a square. We allow ourselves to rotate the square by 0, 90, 180, or 270 degrees and to flip the square about its 4 lines of symmetries. Our identity is clearly a rotation of 0 degrees as this keeps the square fixed. It’s quite clear that we have associativity and closure (if you don’t find this clear then spend some time convincing yourself of it), and we have inverses as the flips are self-inverses while the inverse of a degree rotation is simply a  degree rotation. Note that we are implicitly using modulo 360 here. This group is known as
 , the dihedral group of order 8. Generally, a polygon with vertices has
 symmetries and the group of these symmetries is denoted
 . Note however that some writers denote the group as
 in reference to the number of edges of the polygon. Conventions differ amongst different writers and so elsewhere you may see the group I have spoken of referred to as

Cyclic groups
In group theory, the word order can have two different meanings. When referring to some group  , the order of , written as
 , means the number of elements in the set . If the order of a group is finite then we say that it’s a finite group; otherwise, we refer to it as an infinite group. There is also another definition, but before defining that I’ll first define a few more things.
Let be a group with  . Then, for
 , we define
 . Bare in mind that although you may be accustomed to thinking of
 as meaning
 , this is not necessarily the case. For example, if the operation is addition, then
 and correspondingly
 . A group is said to be cyclic if there exists an element such that
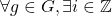 such that
 . That is, every element in is just some power of . If this is the case then we say that is generated by and write that
 .
For example, the additive group  is cyclic as
 . Another example is the multiplicative group of complex fourth roots of unity,
 . This group is cyclic and is generated by
 .
Now for the other definition of order. Let be a group and . The order of , denoted  , is the smallest positive integer such that
 , assuming that such exists, in which case has finite order. If no such exists then we say that has infinite order.
Proposition: Let be a group and . Suppose  . Then:
1. If has infinite order, then  if and only if

2. If  , then if and only if
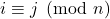
Proof: (1) Suppose that but  . Without loss of generality, suppose that
 Then
 . That is,
 . But
 is a positive integer, and this contradicts the assumption that has infinite order.
(2) Suppose that . Once again, . Using the Euclidean division algorithm, write  with
 and
 . Then
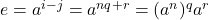 . But and thus
 . But since is the smallest positive integer having this property and
 , it must be that
 . And hence
 as desired. Conversely, suppose that . Then let us write
 for some
 . But we now have that
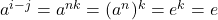 . Thus
 and hence as desired.

In these two proofs, we have assumed that if is an element of some group and  and are integers, then
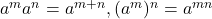 and
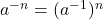 . Thankfully, these are all true. The proofs are not difficult and so are left as exercises for the reader.
A useful corollary of the second proposition is that for a group with some element of order  and some integer ,
 if and only if

Subgroups
For some group , we define  , a subset of , to be a subgroup of if is also a group under the same operation and write
 . For every group, the group itself and
 are both subgroups. We refer to a subgroup as a proper subgroup when it is a group other than itself.
For example, we can see that is a subgroup of  and both are subgroups of with addition as the operation. So, what determines whether a group is a subgroup of another group or not?
Theorem: Let be a group and a subset of . Then if and only if:
1. 
2. 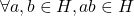
3. 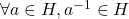
Proof: If is a subgroup of , it must have an identity element  such that
 but we also have that
 . Hence
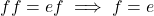 as required. By the definition of a group, the second and third condition must hold. Conversely, let’s suppose that the conditions hold. Clearly, the conditions guarantee the existence of an identity element, closure, and the existence of inverses of each element. Associativity is inherited from and so satisfies the four axioms and is indeed a subgroup of .
Commutativity
A convenient feature of addition over the integers is that when adding two integers, it doesn’t matter what order we add them; 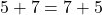 and generally:
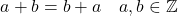
This property is known as commutativity and is present in practically all of the groups we tend to encounter in pre-university mathematics. However, there are many groups that don’t have this property. Matrix multiplication, for example, isn’t commutative, and nor is the composition of symmetries. Groups in which all elements commute are known as abelian groups. It can be useful to know which elements of a group commute regardless of whether a group is abelian or not, and so we refer to elements of a group, , that commute with all other elements in as the centre of the group,  . For example, the centre of the group with operation matrix multiplication acting on the set of invertible
 matrices with entries in is the set of matrices:


